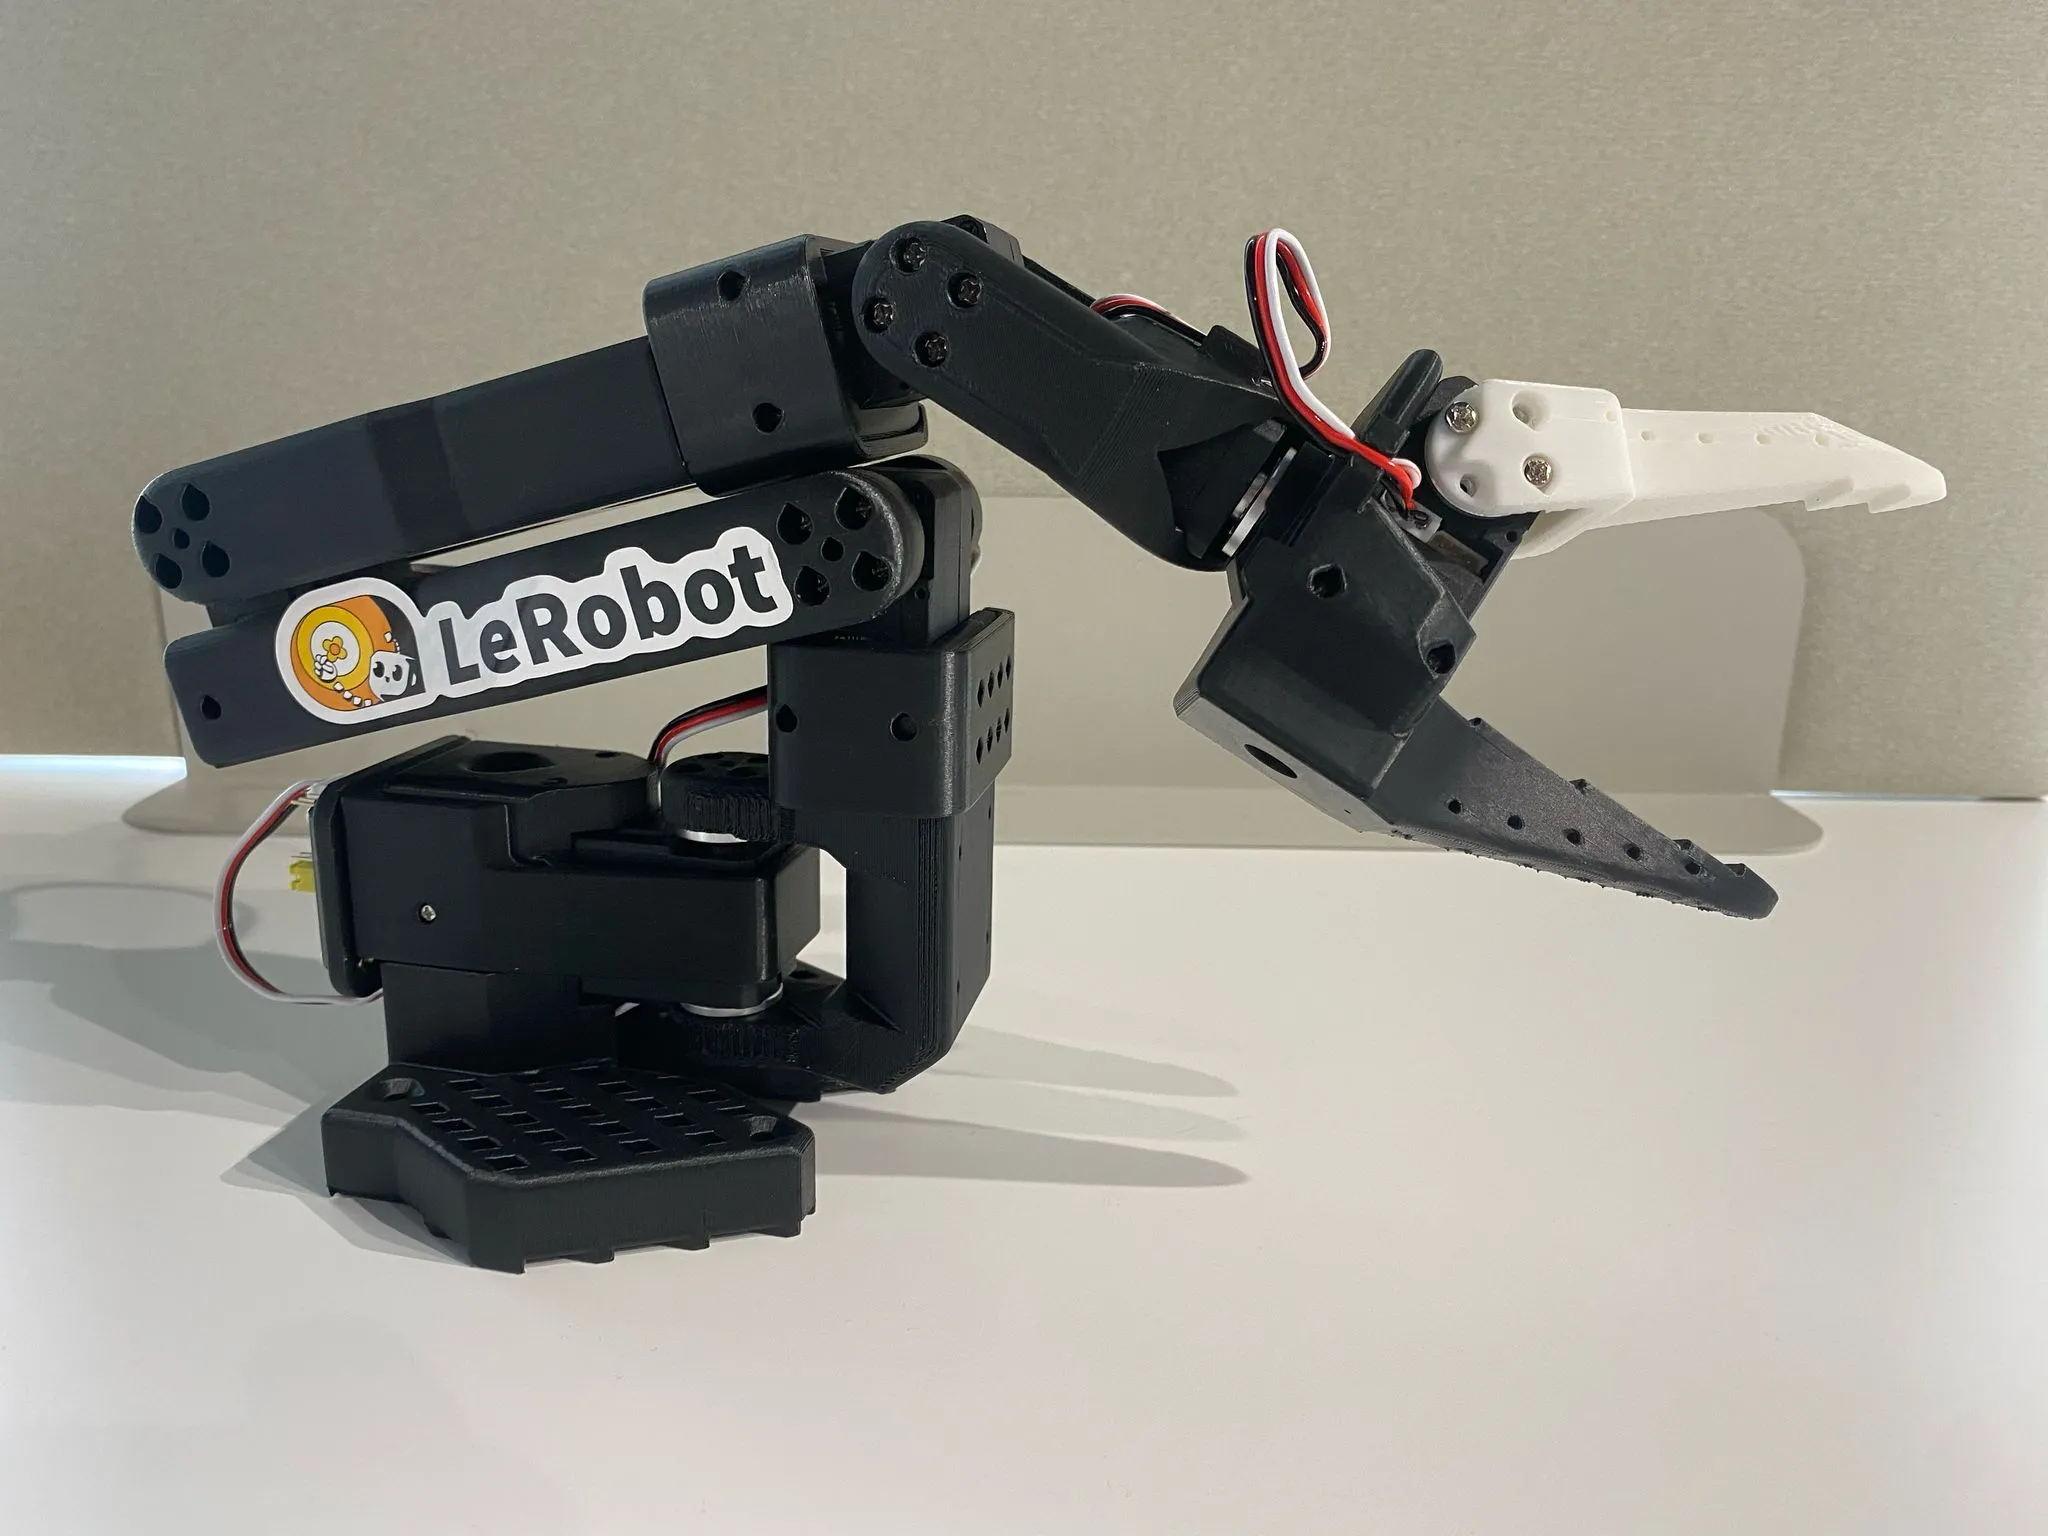
Training recipe · SO-101
SO-101 PPO to LeRobot: 1,000 filtered simulation demonstrations
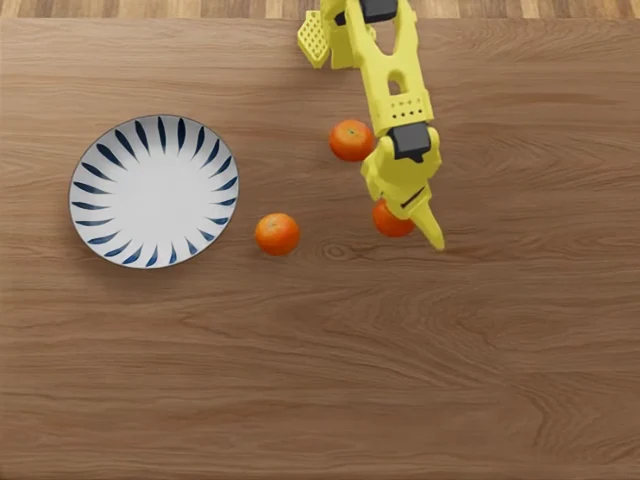
A simulated cap-to-tray task, adapted from NVIDIA's SO-101 workshop in Isaac Sim / Isaac Lab, uses a learned state-based PPO policy to generate 1,000 filtered LeRobot v3 demonstrations with top and wrist RGB. Simulation data generation; real-world transfer and SmolVLA improvement are not yet demonstrated.
DocumentationTraining code
Created by Burak Barlas / Verapulse
Shared by Community member