Dataset · SO101 (simulated)
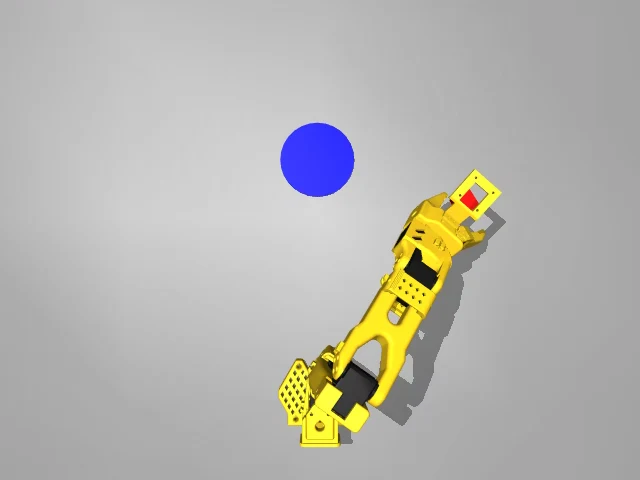
SO101 simulated pick-and-place demonstrations
A small LeRobot v3 dataset of MuJoCo SO101 demonstrations linked by the SO101-Nexus author.
About this project
The dataset card exposes action/state fields, wrist and overhead videos, and metadata reporting ten episodes at 30 fps. SO101-Nexus identifies it as simulation teleoperation data. This is a dataset resource, with no trained checkpoint attached.
Setup & reproduction
Use a LeRobot v3 reader and compare the metadata with the intended environment. Verify camera placement, calibration conventions and action units before using the demonstrations for another setup.
Sources checked 2026-09-21. Shared by a community member; original work by johnsutor.
- Source: https://huggingface.co/datasets/johnsutor/MuJoCoPickAndPlace-v1
- Source: https://github.com/johnsutor/so101-nexus Known limits:
- Immutable resource revisions have not been captured; linked default branches/cards can change.
- No independent installation, policy evaluation or hardware reproduction was performed.
- Immutable dataset and collection-environment revisions are unknown.
- Task success counts and compatibility with other checkpoints were not verified.
Restored from the original local preview catalog; original creator attribution and reviewed source notes are preserved.
Interactive preview
No interactive preview is available for this project. Explore the linked resources and demonstration above.
Discussion
Share what you tried, ask a question, or add a useful detail. Comments appear newest first.
Loading comments…