Training recipe · SO101
Build and calibrate an SO101 for data collection
Official SO101 hardware designs and LeRobot assembly guidance for preparing a leader/follower setup.
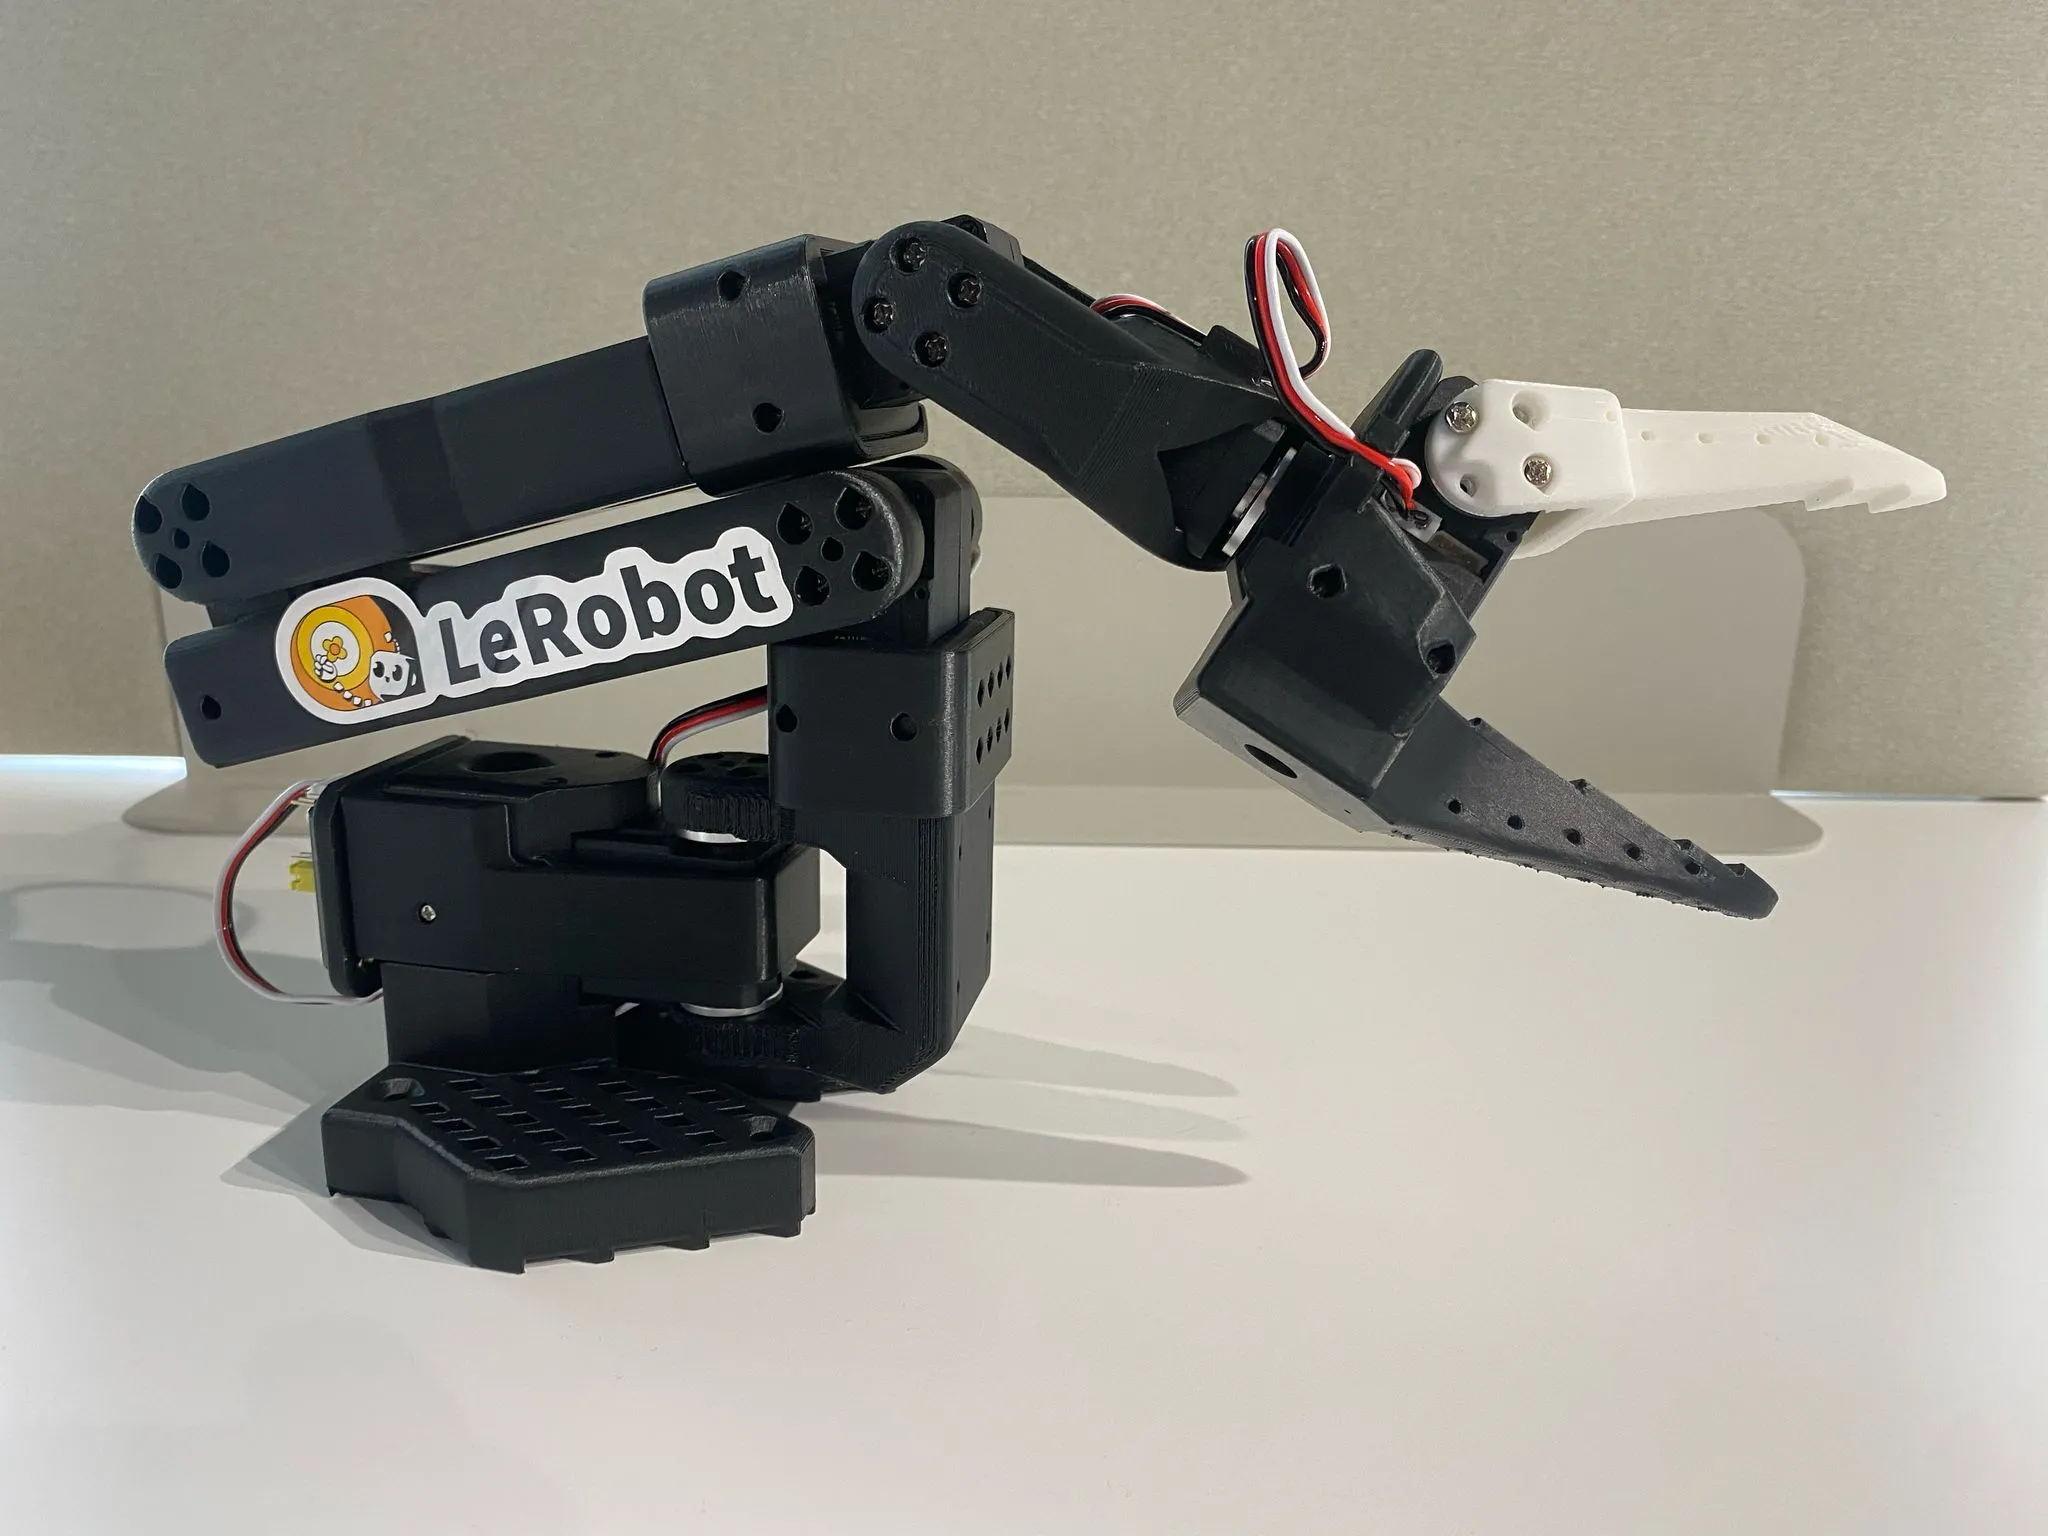
About this project
The Robot Studio repository contains hardware designs and a bill of materials. The linked LeRobot guide covers SO101 assembly and setup. This is a preparation recipe; it does not include a trained task policy.
Setup & reproduction
Choose the matching leader/follower hardware variant, follow its motor and power specifications, install LeRobot with Feetech support, then complete calibration using the official guide.
Sources checked 2026-09-21. Shared by a community member; original work by The Robot Studio and Hugging Face.
- Source: https://github.com/TheRobotStudio/SO-ARM100
- Source: https://huggingface.co/docs/lerobot/so101 Known limits:
- Immutable resource revisions have not been captured; linked default branches/cards can change.
- No independent installation, policy evaluation or hardware reproduction was performed.
- License for the separately hosted documentation has not been verified.
- Selected hardware revision, cameras and local calibration are user-specific.
Restored from the original local preview catalog; original creator attribution and reviewed source notes are preserved.
Interactive preview
No interactive preview is available for this project. Explore the linked resources and demonstration above.
Discussion
Share what you tried, ask a question, or add a useful detail. Comments appear newest first.
Loading comments…